Naichuan Sun

I’m a Ph.D. student at the School of Artificial Intelligence (SAI), Shanghai Jiao Tong University (SJTU), advised by Prof. Yuanbo Xiangli. I completed my undergraduate studies in Automation at the College of Artificial Intelligence, Nankai University. My research interests lie in robotics, with a focus on how robots learn loco-manipulation skills and how world models can support learning in humanoid robots and robotic arms.

Naichuan Sun wearing sunglasses outdoors

Selected Publications and Projects

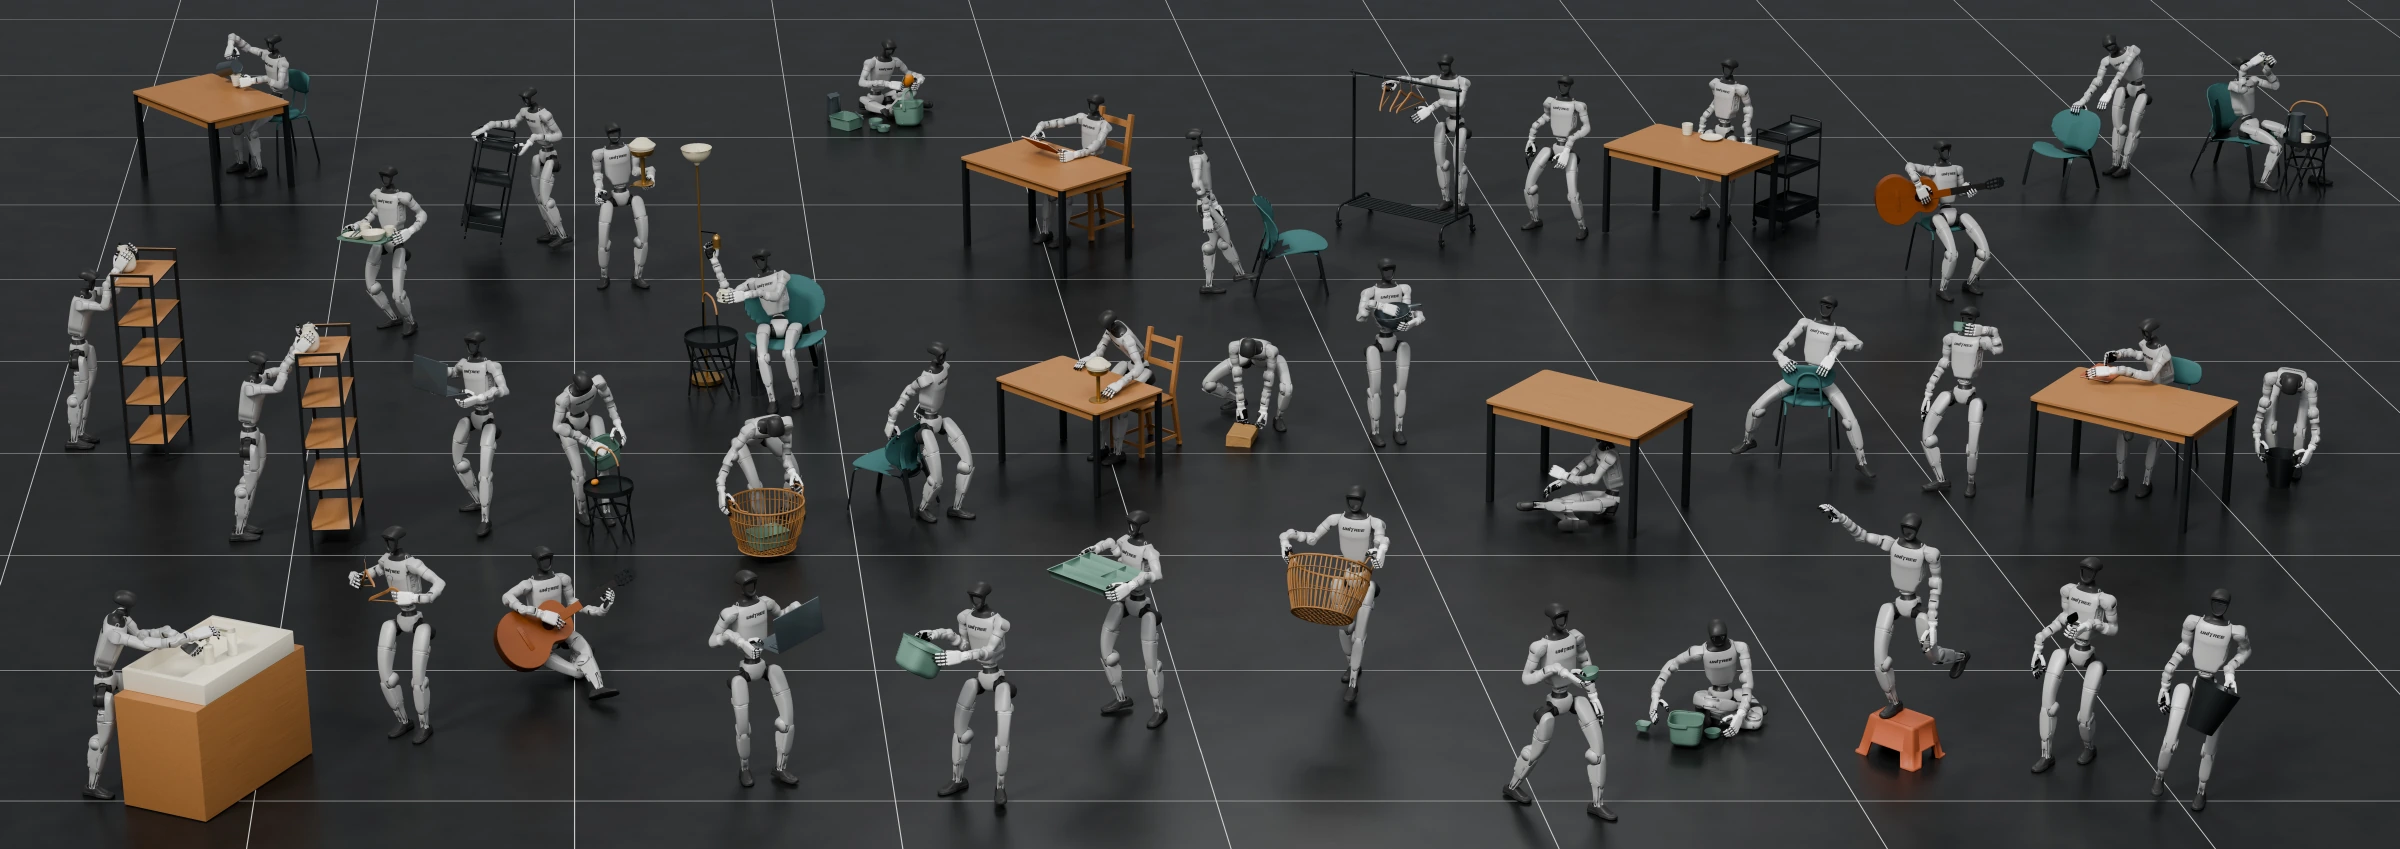
DexWeave enables a Unitree G1 humanoid with dexterous hands to perform whole-body motions and manipulate everyday objects.

DexWeave: Learning Dexterous Humanoid Loco-Manipulation from Human Demonstrations

Naichuan Sun*, Haotian Shen*, Yizhang Zhang, Luying Feng, Haoze Wang, Yuanbo Xiangli, Yaochu Jin, Peidong Liu†

DexWeave combines interaction-consistent whole-body retargeting with anatomy-aware reinforcement learning to enable dexterous humanoid loco-manipulation from human demonstrations.
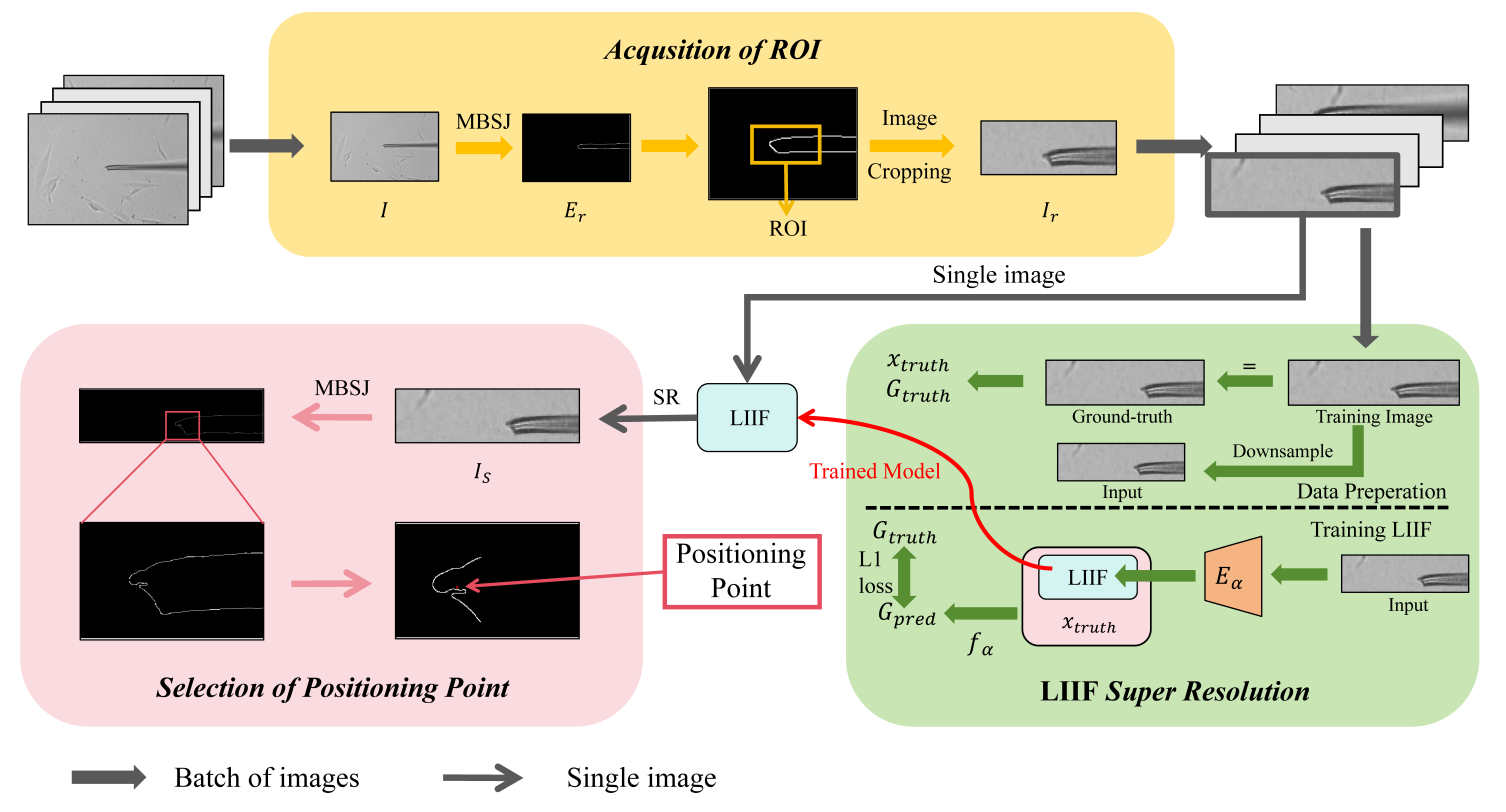
Figure 2 from the paper: region-of-interest acquisition, LIIF super-resolution, and selection of a micropipette positioning point.

Precise Positioning of Micro Manipulation Tools Based on Super-Resolution

Naichuan Sun, Yue Lu, Mingzhu Sun†

44th Chinese Control Conference (CCC), 2025

We propose a micropipette localization method that combines multiple blur scale edge detection with LIIF super-resolution, using the centroid of tip-edge pixels to estimate the tip position.

Paper

Building a Mobile Household Service Robot

Team Leader · Robocompass, Nankai University

Mar. 2023 – Feb. 2024

We built a wheeled robotic platform equipped with a gripper and LiDAR, using YOLO, SLAM, and PID control to perform locomotion and manipulation tasks. Our team won the Space Service Competition at the 2024 World Robot Contest Championship.

Honors and Awards

Educations